A chassis is the mechanical and electrical base
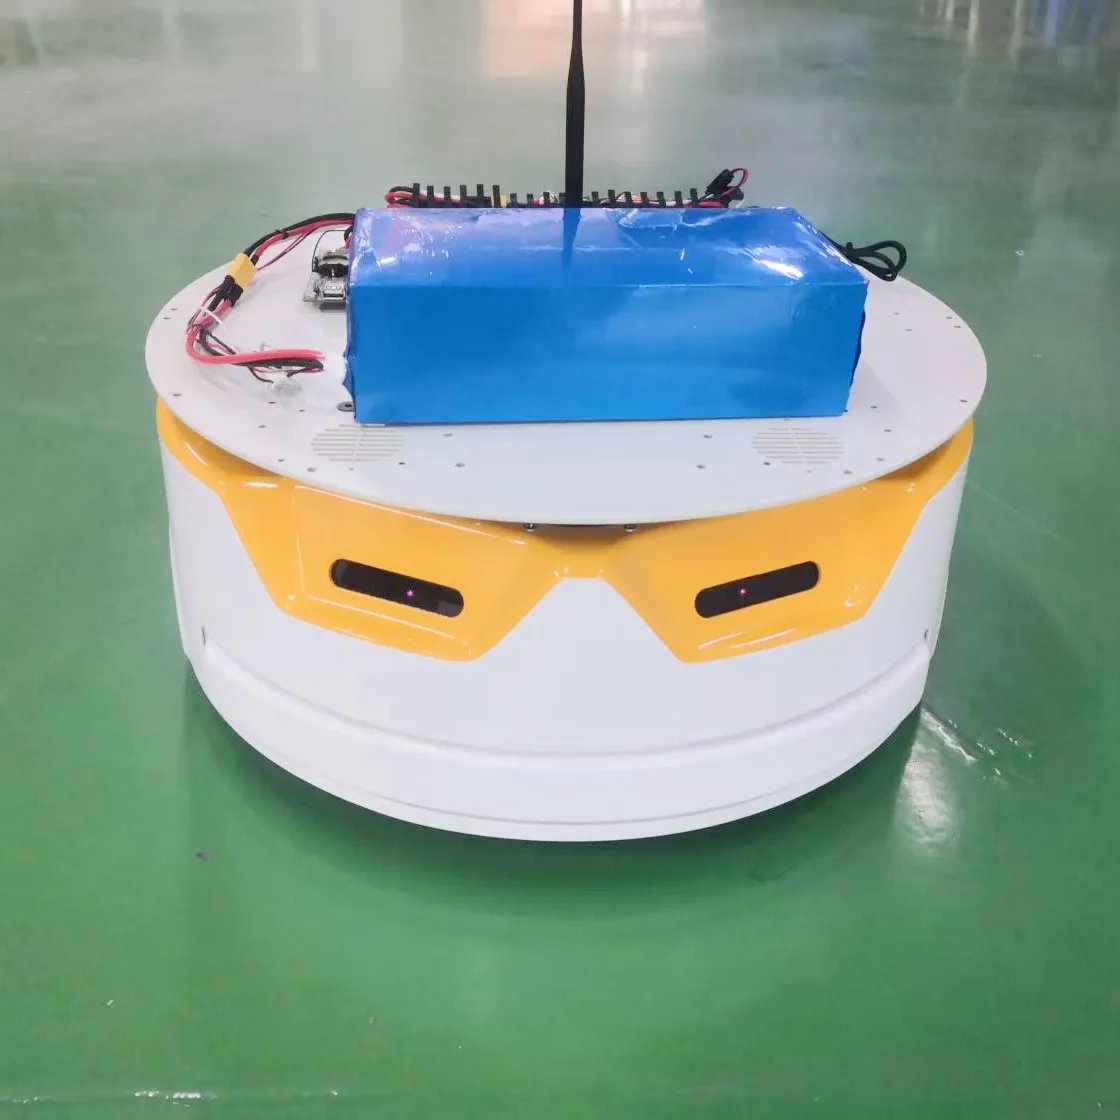
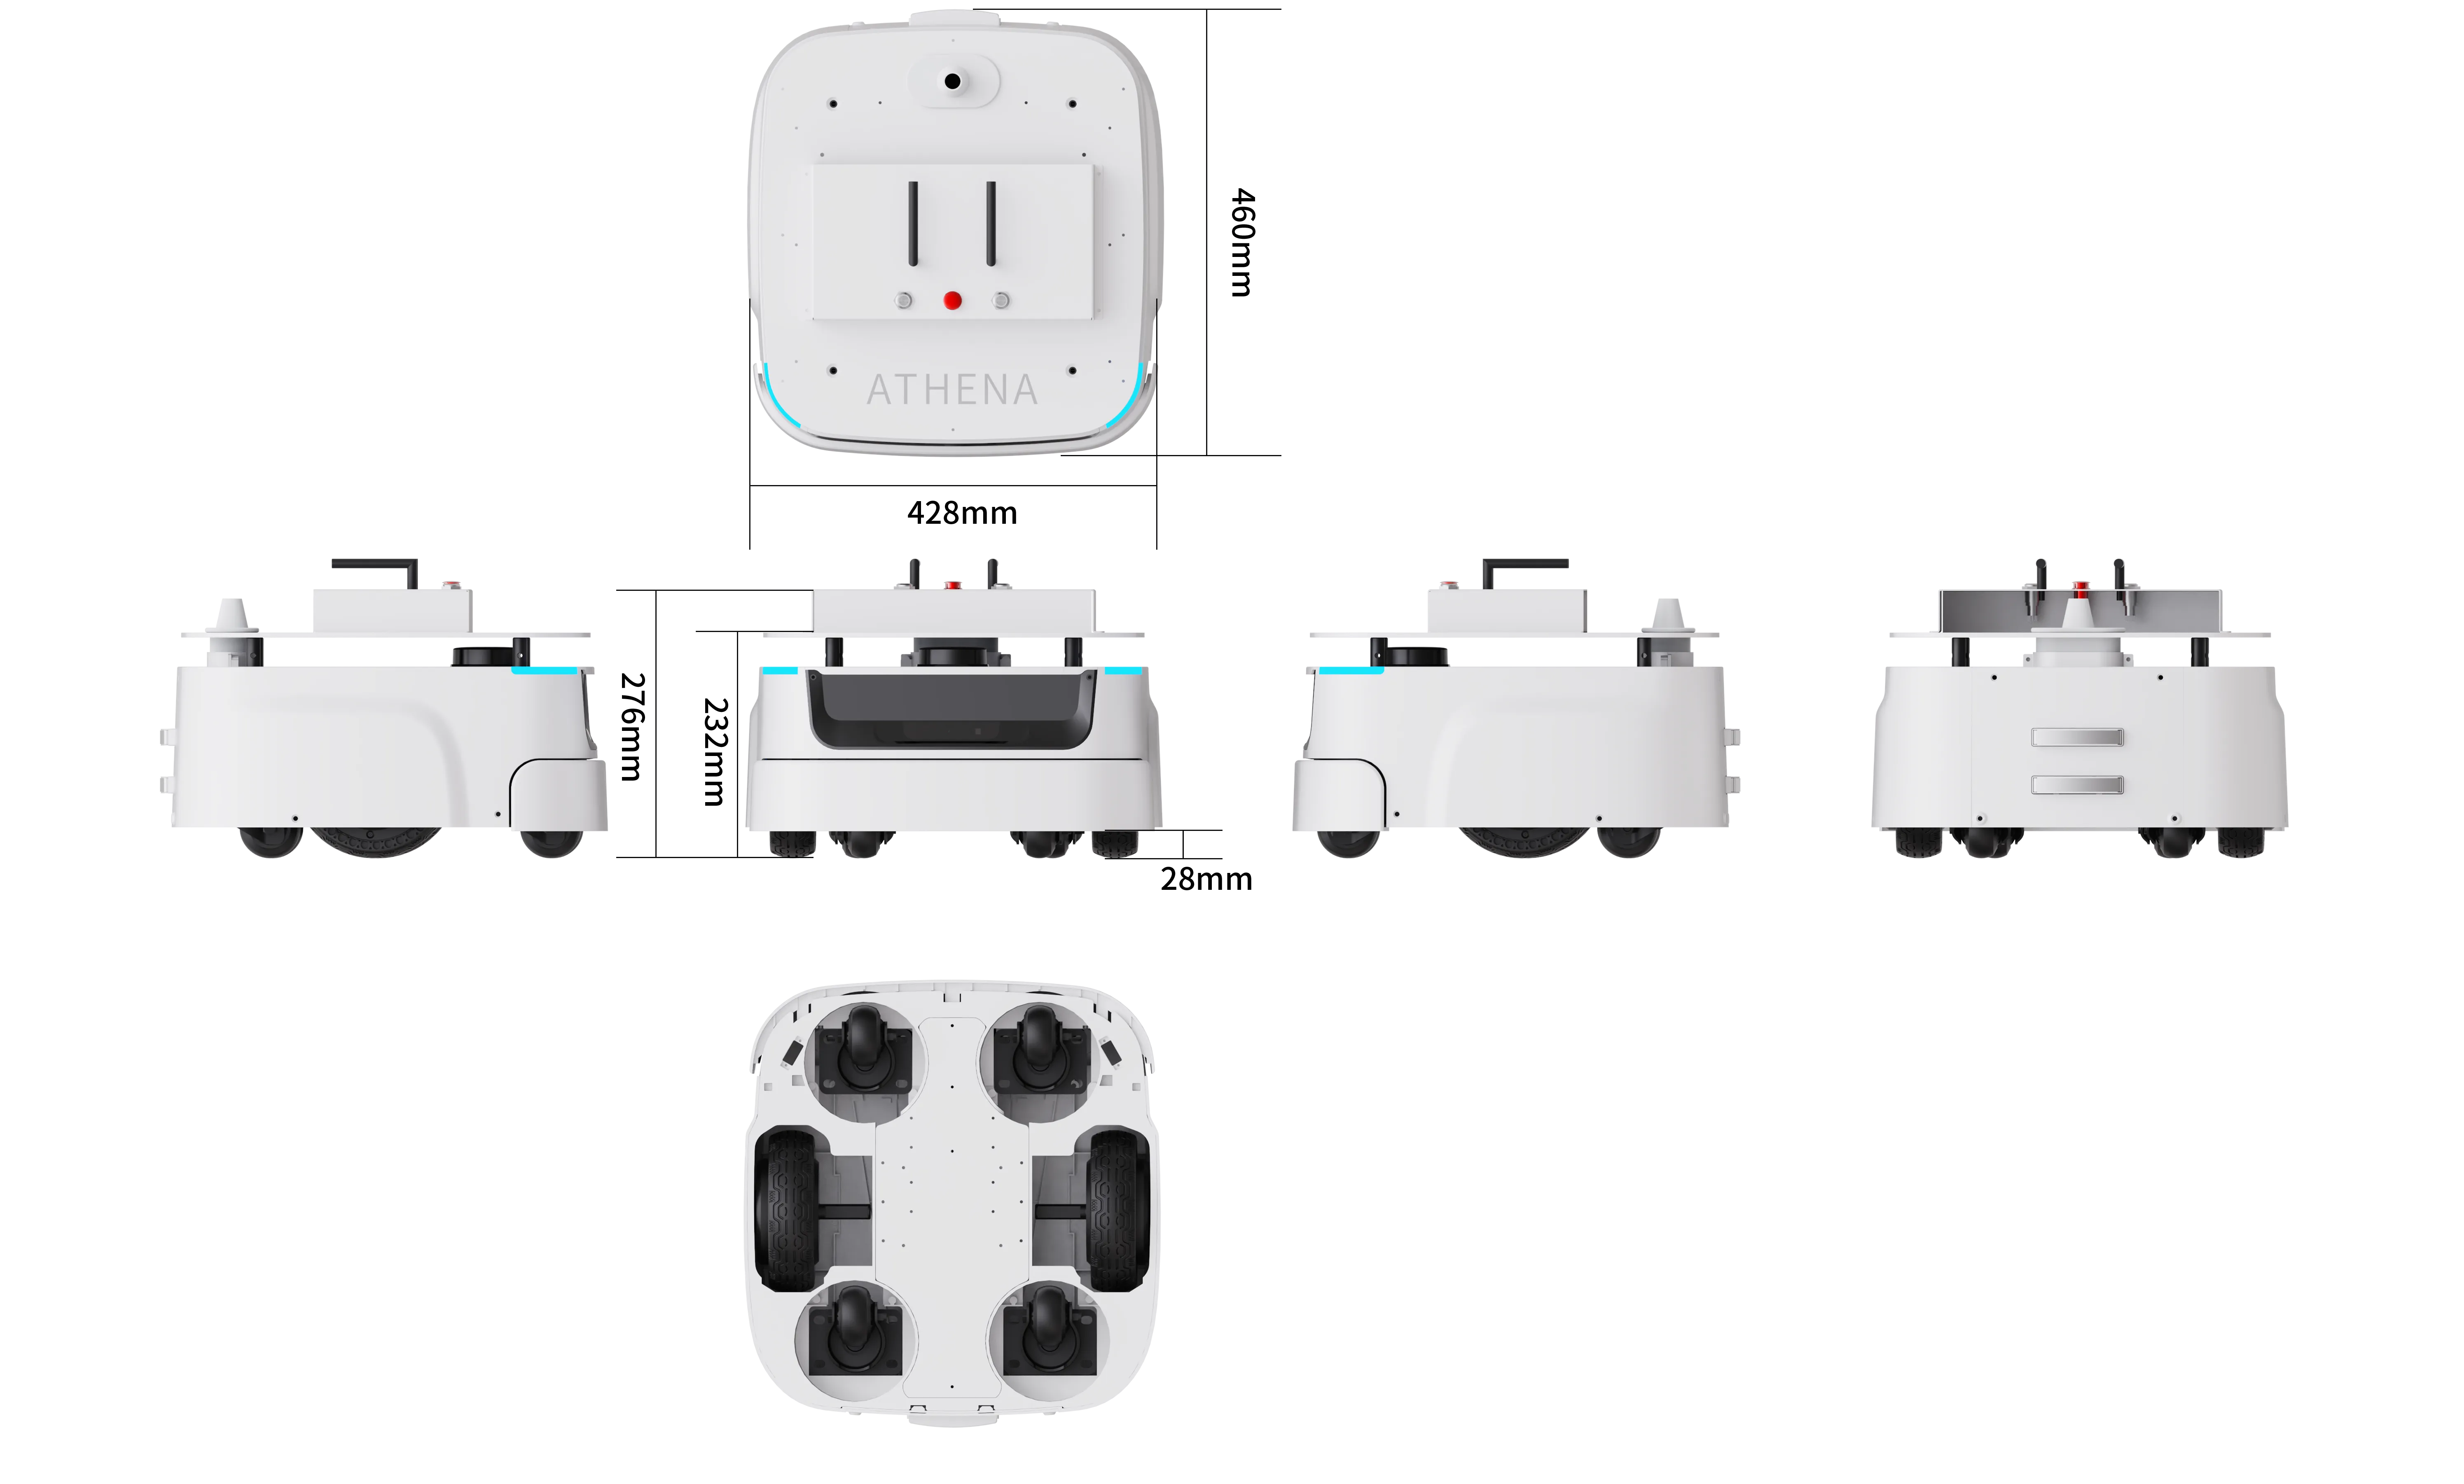
A chassis provides the drivetrain, battery, motor controllers and a mounting deck. Gemini and Gemini-O are examples: 280–350 mm wide bases carrying 10–20 kg, with an exposed deck for your own sensors and computer.
You supply navigation, perception and the application layer. That is the right choice when the research question is the stack itself, not the hardware.
An AMR platform adds sensors, compute and a map
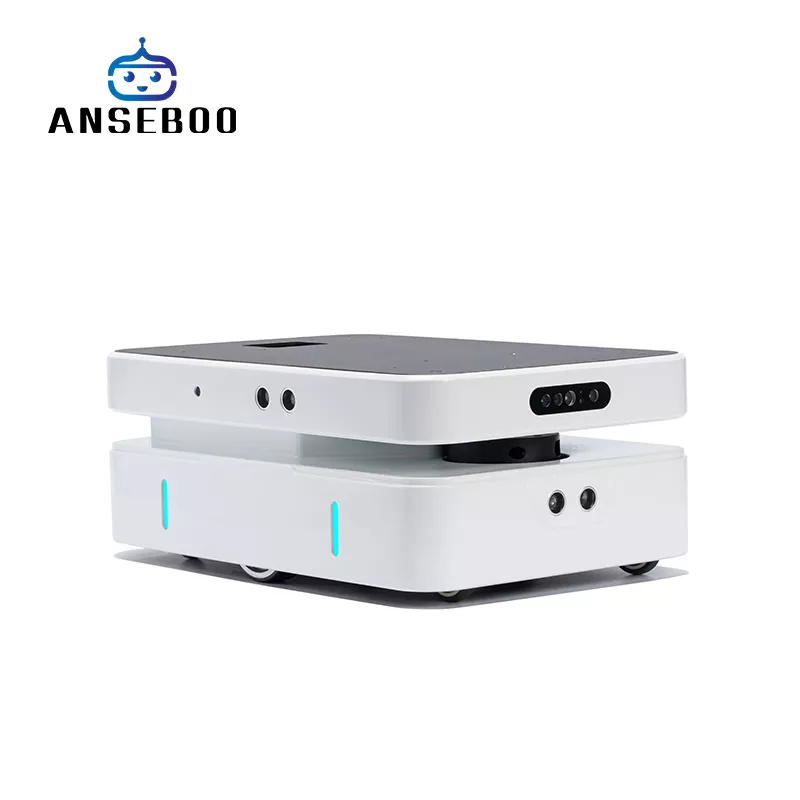
An AMR platform packages the chassis with a LiDAR or depth cameras, an onboard computer and software that builds a map and drives to goals. HA08 and HA09 add a 30 m ToF LiDAR, depth cameras and 50–80 kg of payload on top of the base.
In practice, an AMR platform is what turns a two-month integration into a two-week one — at the cost of less freedom about which sensors and stacks you use.
Where the line actually falls
Ask three questions: does it ship with a navigation stack, does it expose a documented SDK / API, and does it carry the compute to run your perception code? If all three are yes, treat it as an AMR platform regardless of the name in the quotation.
Conversely, a "platform" that only exposes motor commands is a chassis with marketing. The spec table settles it: look for LiDAR range, camera type, ROS version and interfaces.
Which one fits your project
Choose a chassis when the contribution is the algorithm, the budget is tight, and 10–20 kg is enough for sensors and a small computer. Choose an AMR platform when the robot must work in a real corridor soon, or when the payload includes an arm, a screen or a delivery compartment.
Mixed projects are common: start on a chassis for the algorithm, then move the stack onto an AMR platform for field trials. Keeping the ROS version and interfaces similar makes that move cheap.
Antes de pedir
- Ask whether a navigation stack ships, or only motor control.
- Confirm sensor set and range (LiDAR range, depth cameras, camera count).
- Confirm compute: is there an onboard PC, and can you install your own?
- Check payload with your sensors, arm and computer added — not just the base figure.
- Match ROS version and interfaces to what your team already writes.