Payload: weigh everything that rides on the robot
The payload figure in a brochure covers the cargo. On site, it also covers trays, the delivery box, a screen, a tablet and sometimes the mounting bracket. Weigh the full assembly once, then compare it with the limit.
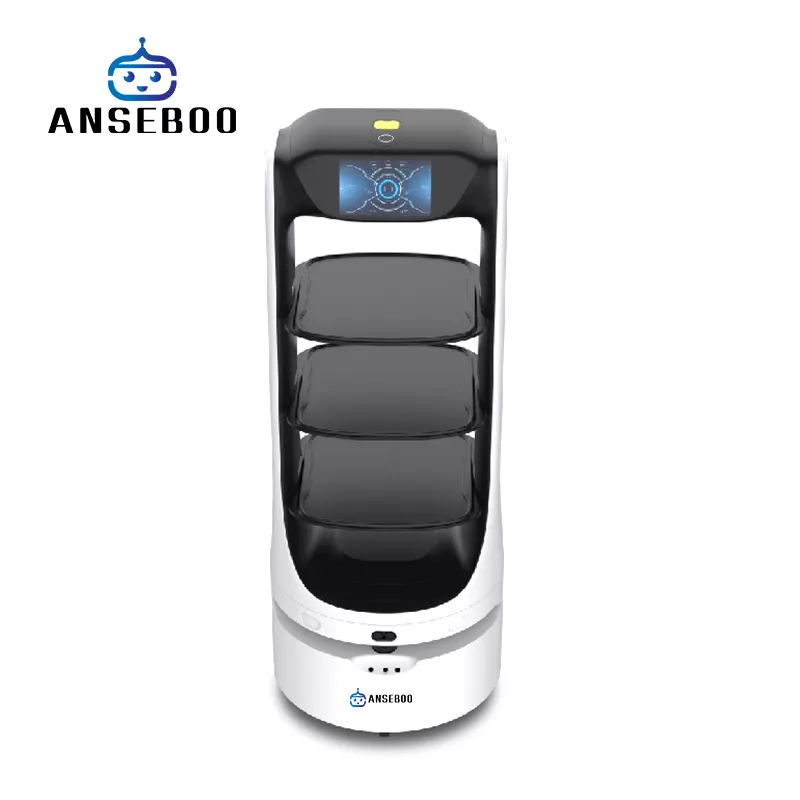
For a restaurant robot, the relevant weight is the heaviest loaded tray, not the average: CA01 and CA02 are tray-service platforms, while FD05 and FD09 declare a 15 kg limit per trip.
For a research platform, add the arm, the onboard PC and the sensors. A 10 kg chassis stops being a 10 kg platform the moment a manipulator is bolted on.
Runtime: measure a cycle, then multiply
Headline runtime is measured at cruising speed on a flat floor. Real cycles are stop-start: waiting at a table, opening a door, queueing at a lift. Time one real cycle with a stopwatch, then divide the usable runtime by it.
Keep 20–30 % of the battery in reserve. A robot that finishes a shift at 5 % charge will not finish the next one, because batteries age faster than their spec sheet suggests.
Charging time is part of the cycle: 2–4 hours for CA01 and CA02, 4 hours for the Gemini chassis, automatic docking on FD05, AS07 and AS10.
Navigation: test the floor, not the datasheet
Laser navigation with obstacle avoidance is now standard, so the differentiator is the floor itself: glass walls, mirrors, trolleys left in corridors, and guests who step in front of the robot.
Map maintenance matters as much as mapping. Ask how the map is updated when a display moves, and whether the robot re-localises after being lifted. A robot that needs a technician after every furniture change will not stay in service.
Sensor range sets the speed limit in practice: a 25 m laser on CA01 or CA02 sees a corridor before it enters it; a 30 m ToF LiDAR on HA08 and HA09 gives research platforms similar headroom.
Environment: the requirements nobody puts in the tender
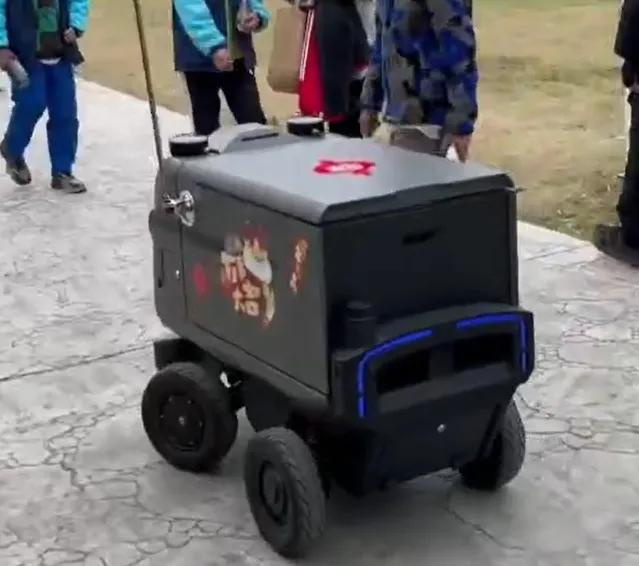
Ramps up to 5° are common at doorways; the outdoor Alout handles 10° and a 1.5 m turning radius. Elevators and doors need controllers that accept a robot call, and a fallback plan for when they do not.
Floor surface changes traction and wheel wear: polished stone, carpet and outdoor paving are three different duty cycles. Ask which wheel compound the model ships with before a fleet order.
Vor der Bestellung
- Weigh the fully loaded robot assembly, including trays, screens and brackets.
- Time one real delivery cycle, then divide usable runtime by it and keep 20–30 % reserve.
- Include charging time in the daily plan (2–4 hours typical).
- Walk the route and list glass, mirrors, ramps, lifts and narrow gaps.
- Ask how maps are updated and how the robot recovers after being moved.
- Confirm wheel type and spare parts for your floor surfaces.